Ai based Autonomous Mobile Robot Navigation
Active
Description
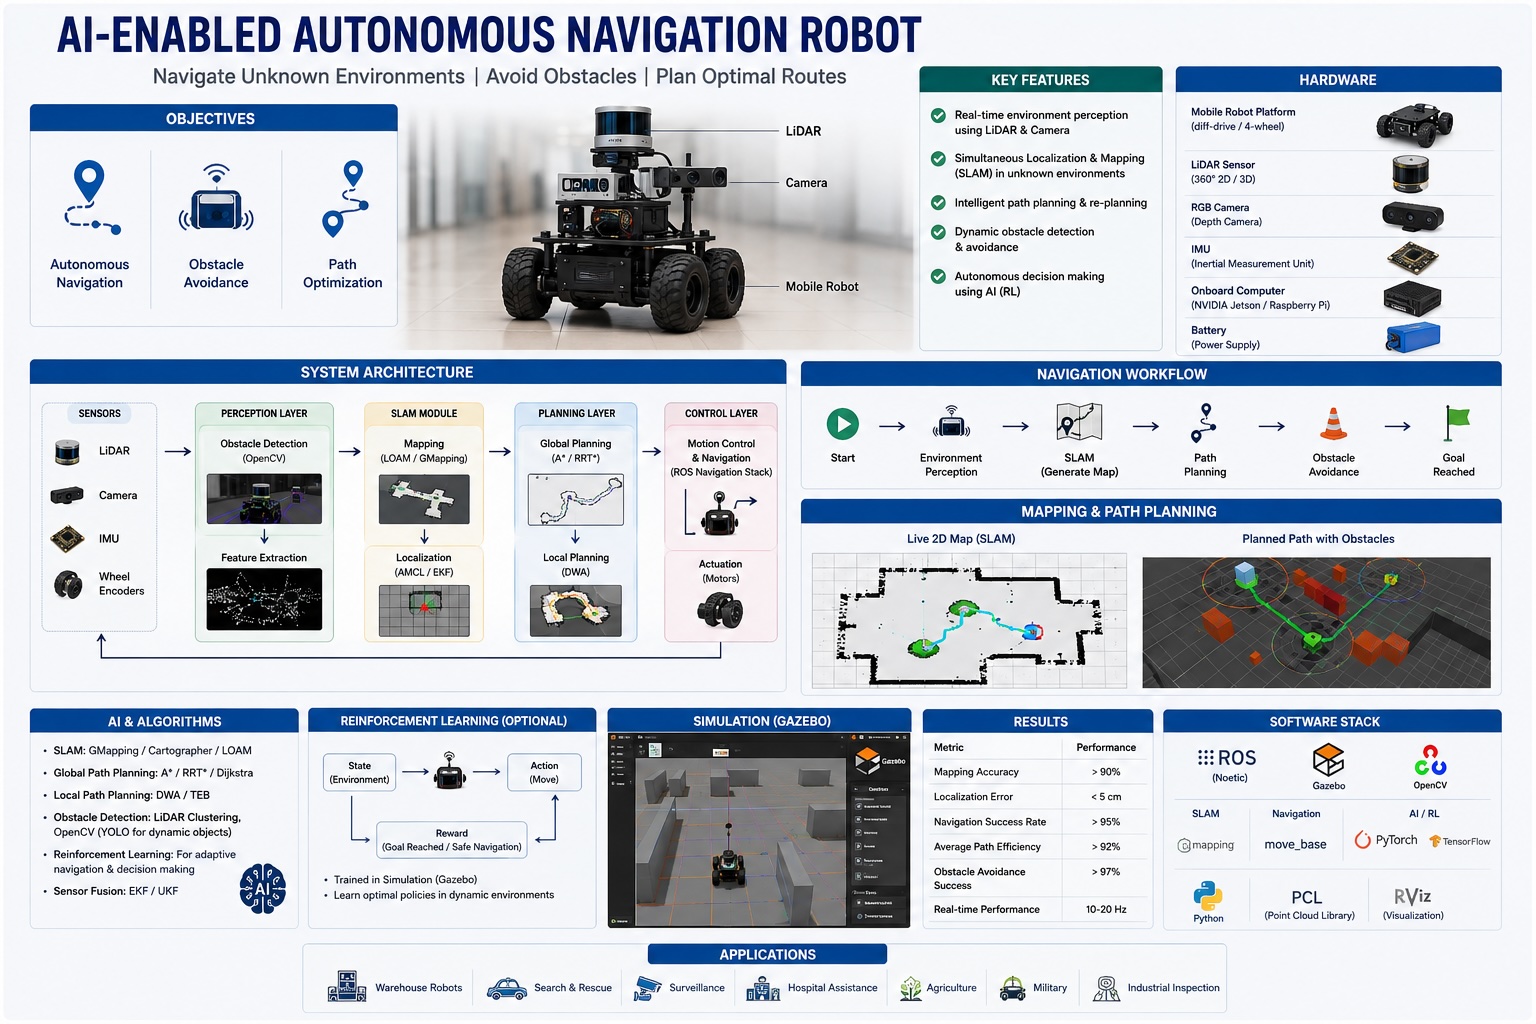
Develop an AI-enabled robot that can navigate unknown environments by detecting obstacles and planning optimal routes.
Objectives
- Autonomous navigation
- Obstacle avoidance
- Path optimization
Prerequisites Skills
- Robotics
- Python
Concepts
- Reinforcement Learning
- SLAM
- Path Planning
Software
- ROS
- Gazebo
- OpenCV
Hardware
- Mobile Robot Platform
- LiDAR
- Camera
Pre-requisites
- Robotics
- Python
- ROS
- Gazebo
- OpenCV
Start Date: 2026-08-09
End Date: 2026-12-31
Estimated Hours: 100
Department : ["9"]
Apply for this Project
Please login to apply for this project and access full features.
Login to Apply